
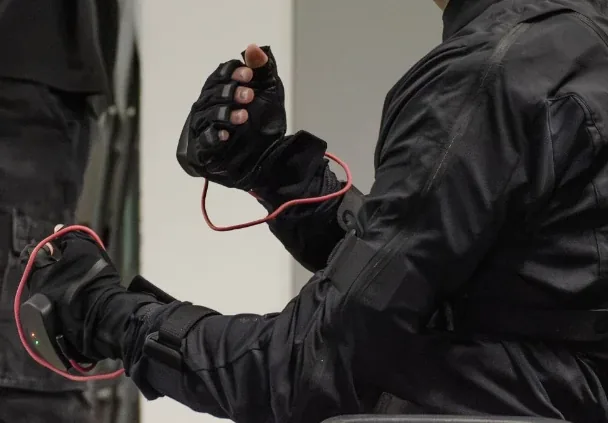
Glove data for robot learning
Build a set of repeatable human demonstrations for a manipulation task. Record how each attempt starts, what the hand does and how the task ends.
Choose a workflow based on what you need to record, control or feel. Each application links to relevant glove configurations and a pilot you can plan around your own task.
Build a set of repeatable human demonstrations for a manipulation task. Record how each attempt starts, what the hand does and how the task ends.
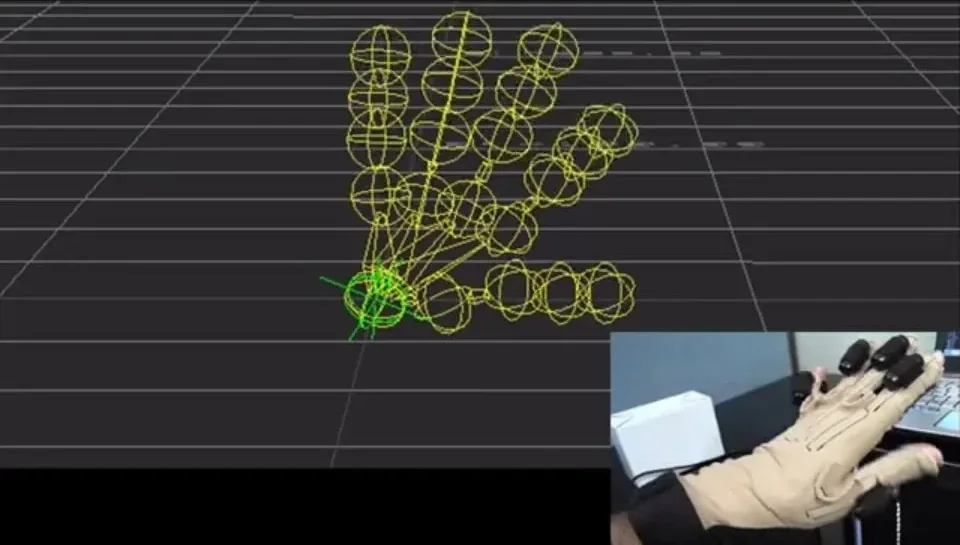
Map an operator’s finger motion to the joints and grasp patterns of a target robot hand. Establish the mapping and its limits before evaluating the full task.
Record how the hand moves and when it contacts an object. Use aligned motion and pressure signals to study the sequence from approach to release.
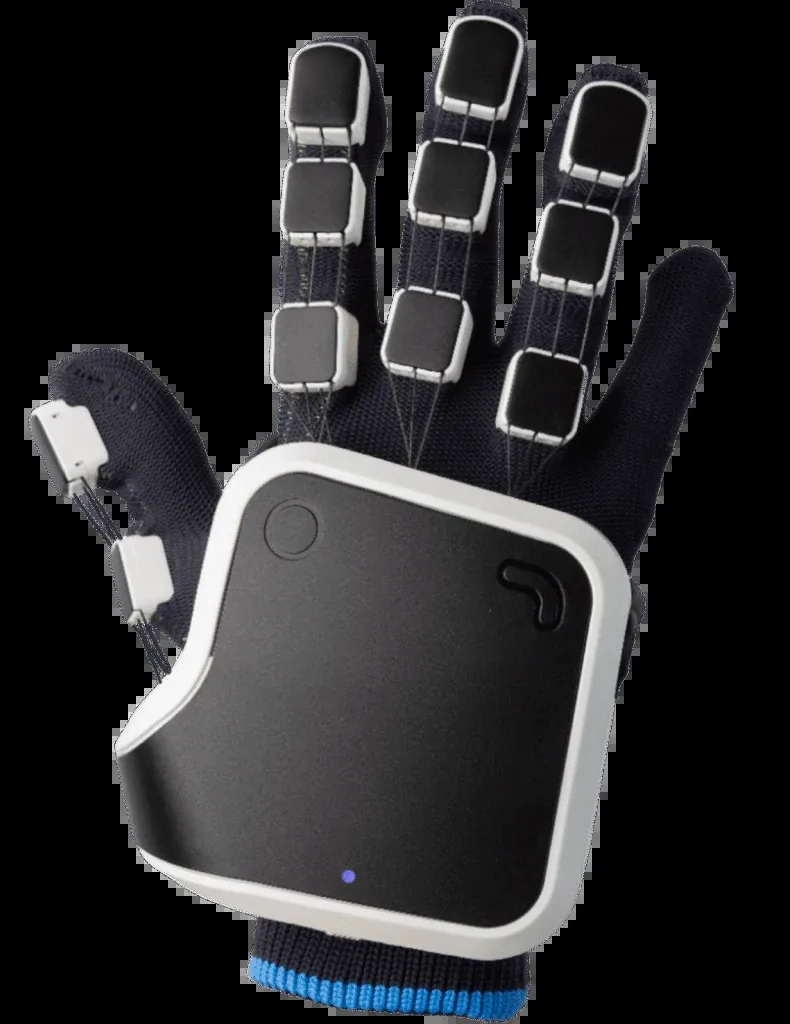
Use vibration to signal an event, finger resistance to represent a grasp limit, or distributed tactile contact to explore where an object touches the hand.
Share the target robot or simulator, the object and task, and the signals you need to record.