
Evaluate a glove for robot training
Run a repeatable grasp and check the signals and data export for the configuration you plan to use. Use those results to decide whether to scale up collection.
Plan a data collection trial ↗ZX-Sensor-Glove-001 · TACTILE DATA COLLECTION
Give your robot learning team contact data to review alongside human demonstrations, from the first touch to the moment the hand lets go.
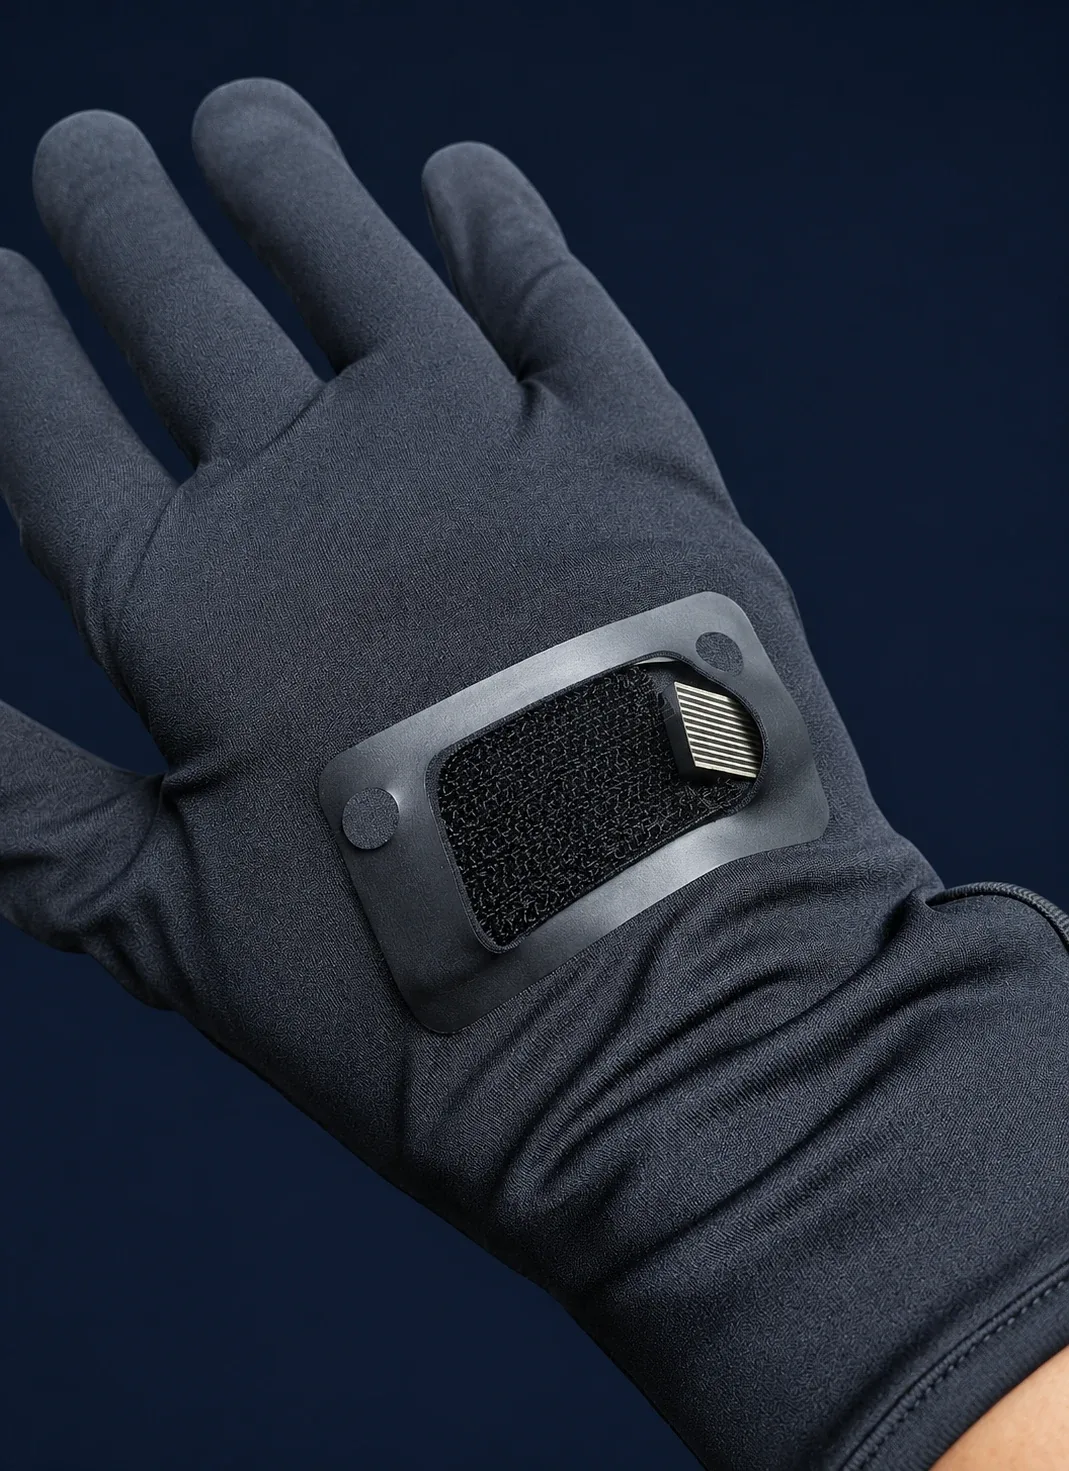
See the fit at the fingertips and wrist, the back-of-hand mount, and the wiring in an open sample.
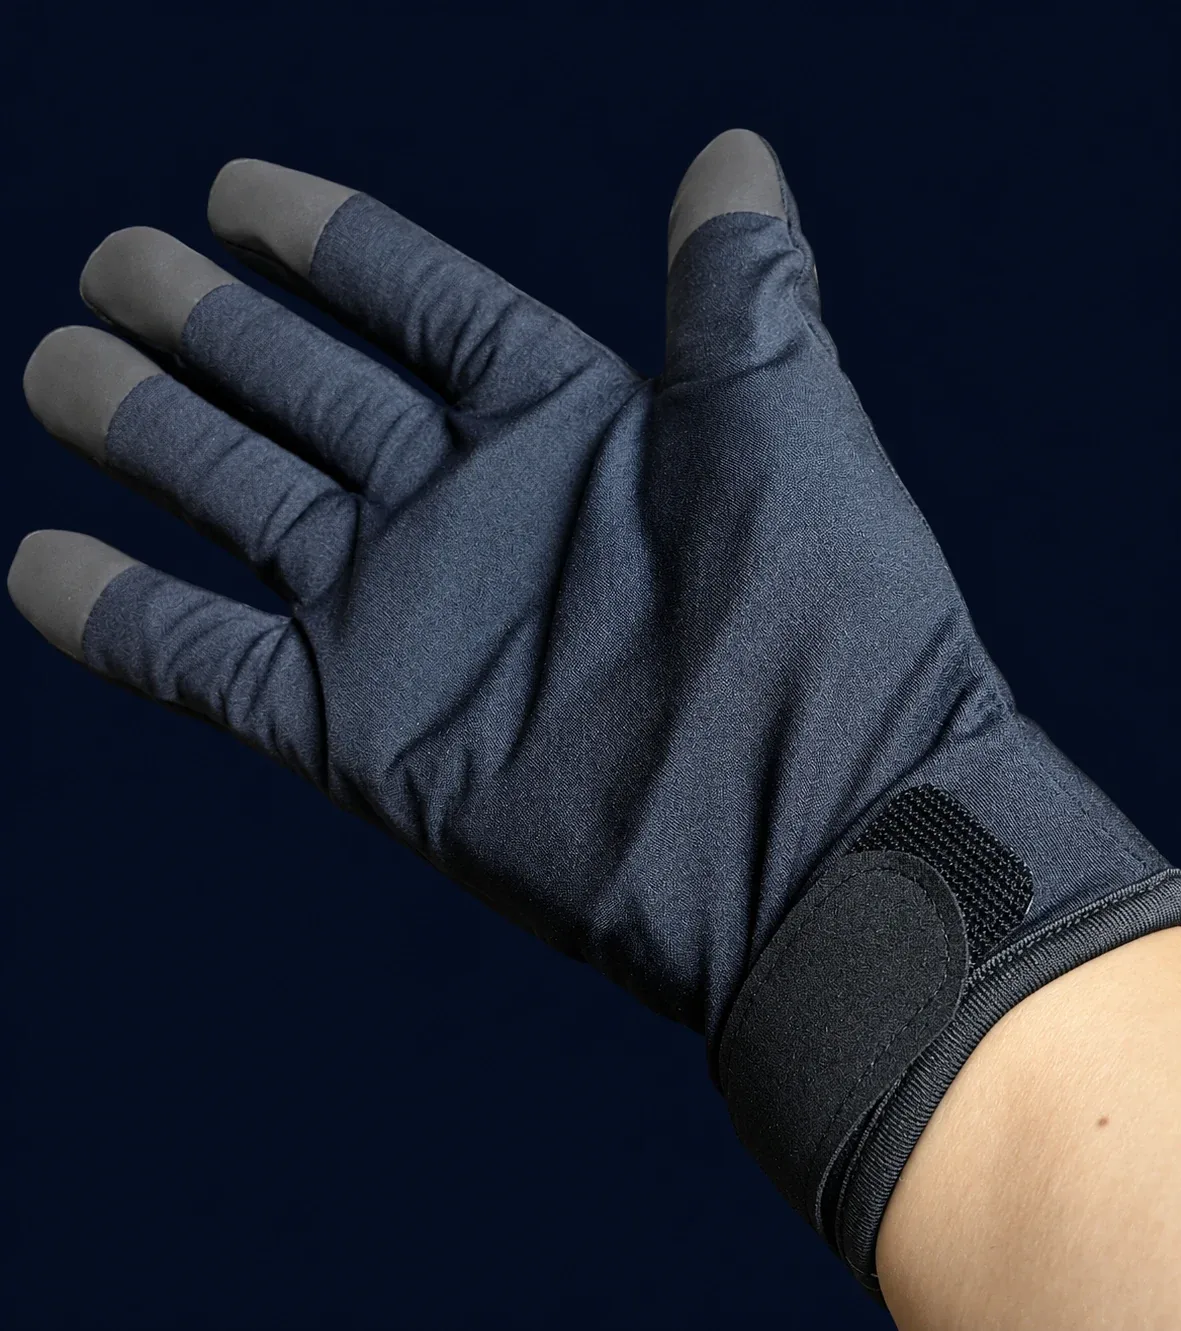
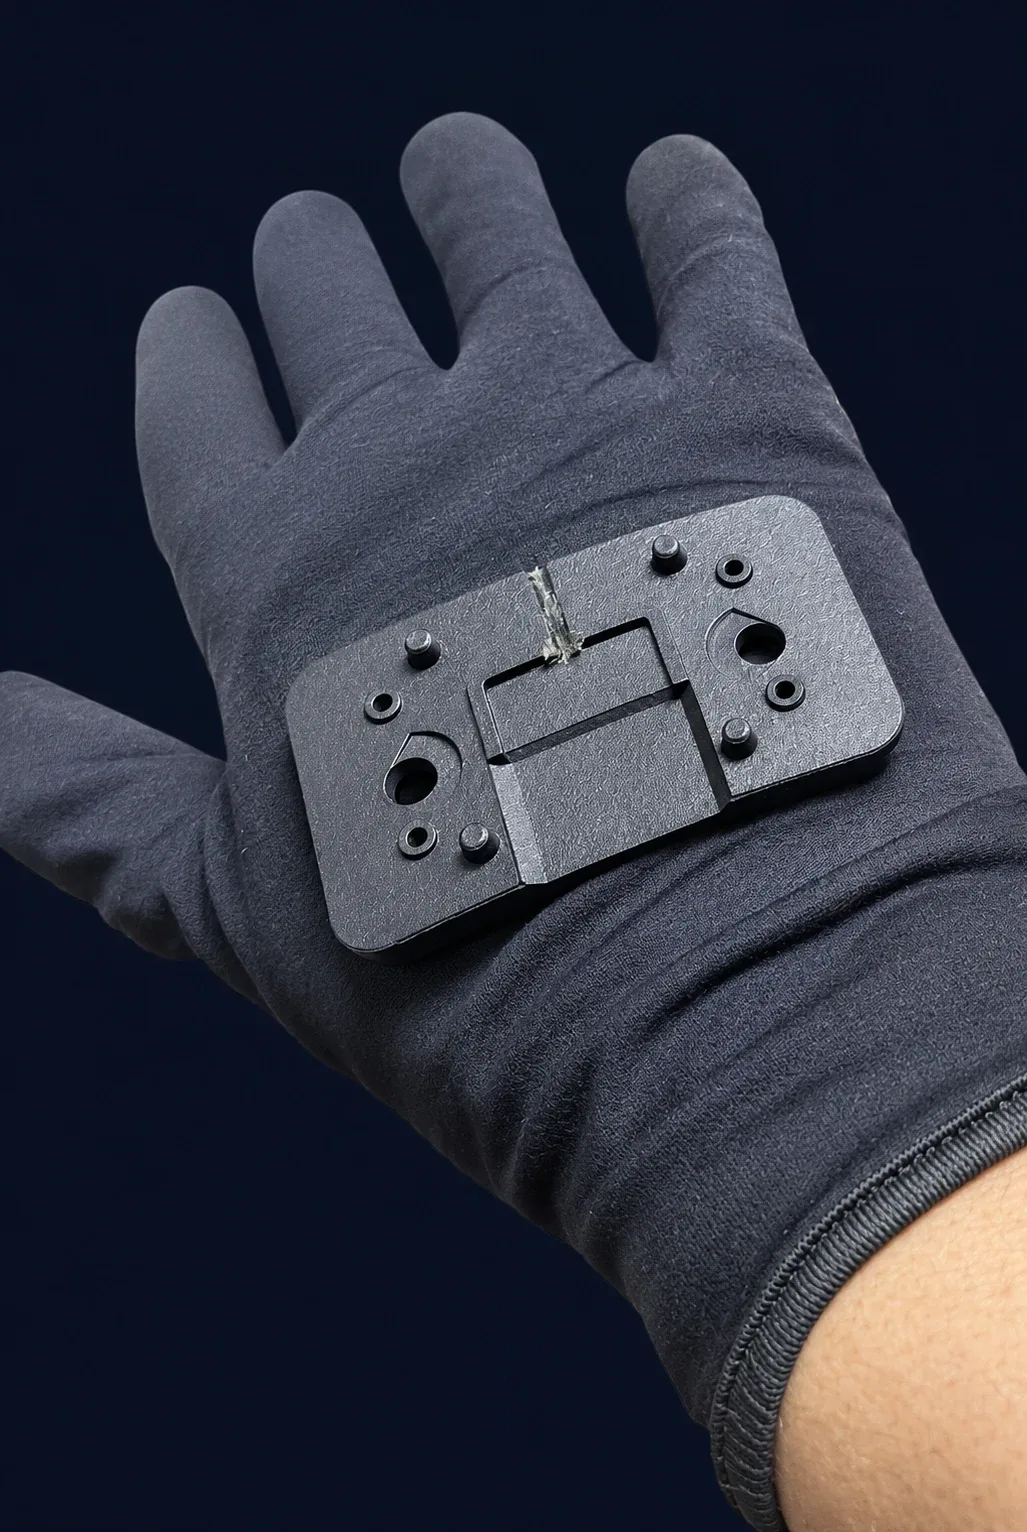
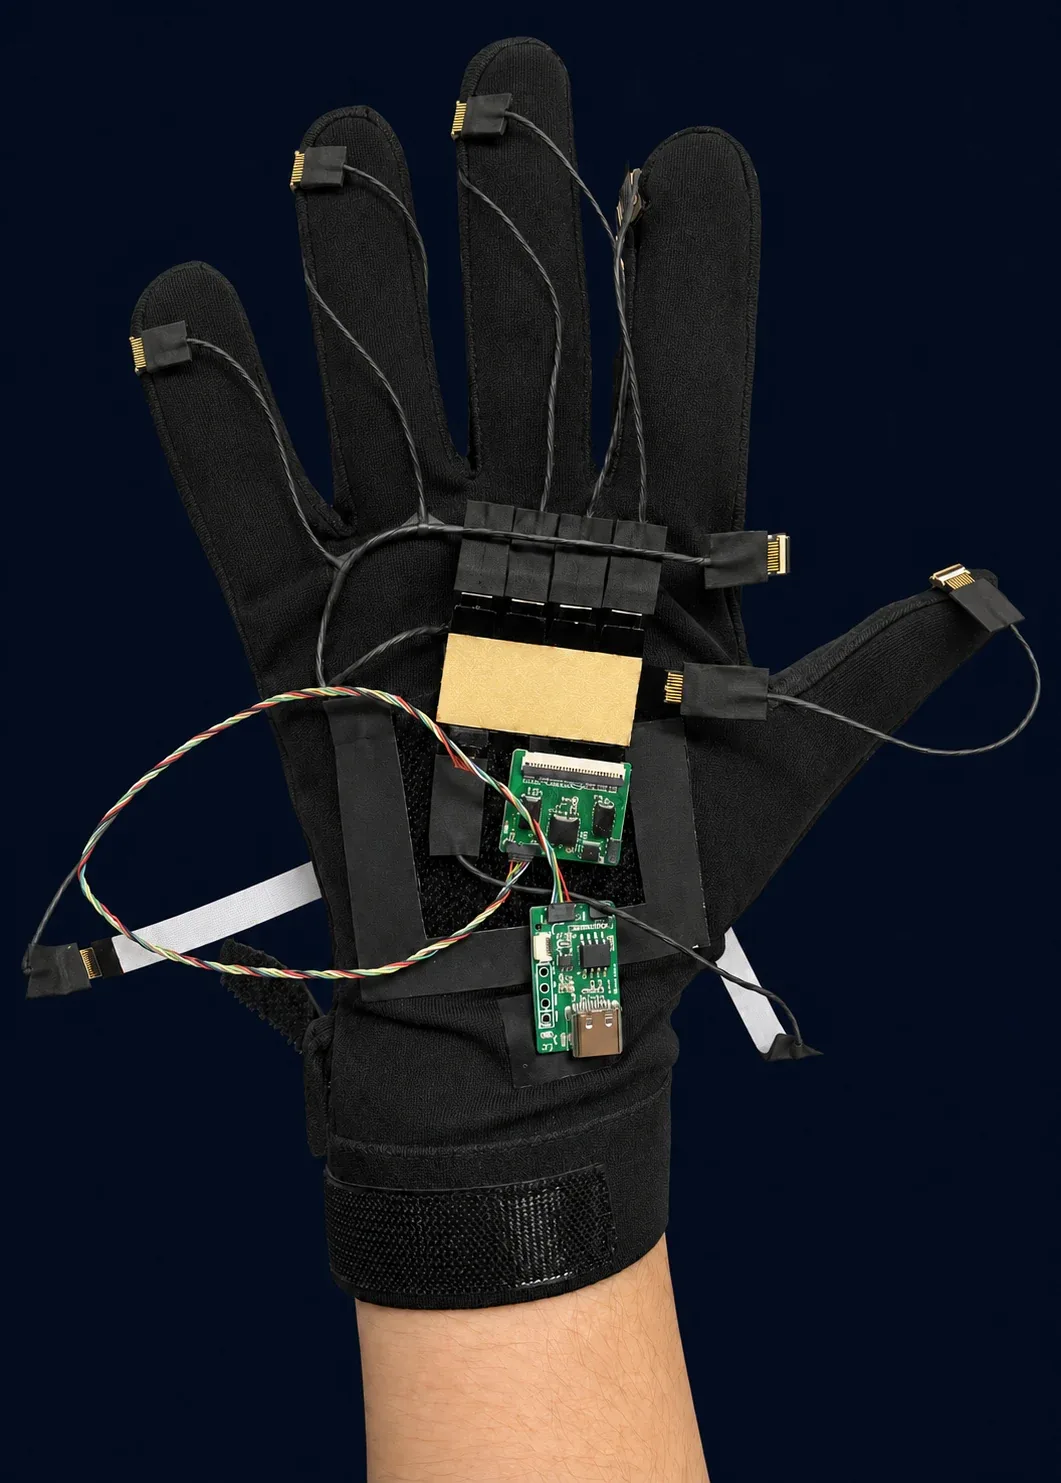
Run a repeatable grasp and check the signals and data export for the configuration you plan to use. Use those results to decide whether to scale up collection.
Plan a data collection trial ↗Share your chip, connector and cable dimensions. We can develop the glove construction with you or manufacture to an agreed design after you approve a sample.
See the sampling process ↗Use one object for a repeatable trial and match the contact data to each stage of the task.
Identify when the hand first touches the object.
Review how the contact signal changes while the object is held.
Mark when the hand lets go and compare repeated trials.
Confirm sensing locations, signal definitions, sampling, data export and software for the selected glove.
Evaluation checklist ↗PRODUCT KNOWLEDGE