
ZIXITECH · GLOVE CONFIGURATION
ZX-Haptic-Data-Glove-001
Hand motion, fingertip pressure and programmable vibration in a paired glove system.
Observe how the hand moves and where fingers press, then deliver individual fingertip cues during interaction.
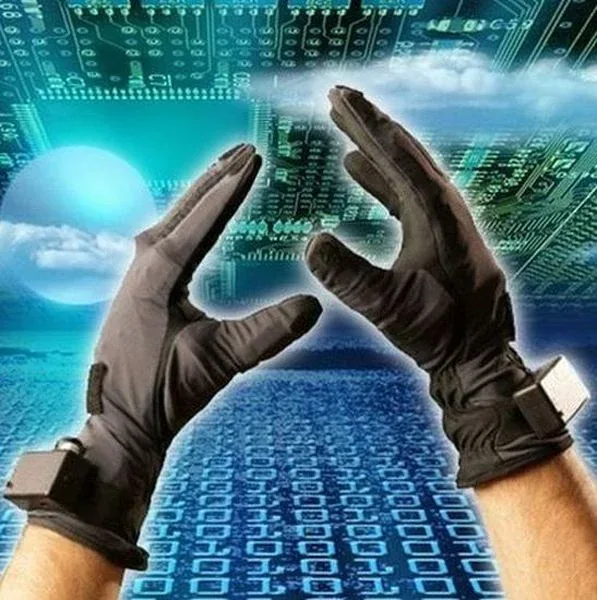
30Sensor data glove
5Fingertip pressure sensors
5Vibration actuators
Configuration profile
| Item | Specification |
|---|---|
| Sensor configuration | 30-sensor data glove |
| Finger bend sensing | Three sensors per finger |
| Finger spread sensing | Four abduction sensors |
| Palm and thumb sensing | One palm-arch and one thumb-crossover sensor |
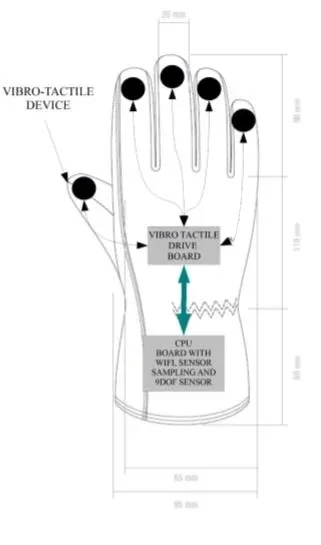
| Pressure sensing | Five fingertip pressure sensors |
| Vibration feedback | Five independently programmable fingertip actuators |
| Orientation sensing | Gyroscope, accelerometer and magnetometer |
| Bend sensor thickness | Less than 0.35 mm |
| ADC resolution | 12 bit |
| Processor | 32 MHz |
| Connection | Wired USB or wireless Bluetooth |
| Battery operation | Up to 5 hours |
| Glove set | Left and right gloves |
Specifications describe the reference configuration. Hardware, software and accessories are agreed for each project.
Plan the integration
- Calibrate bend, spread and hand orientation for the wearer.
- Check the five pressure channels using a repeatable contact.
- Program fingertip vibration and record the input signals and feedback events.