
ZIXITECH · GLOVE CONFIGURATION
ZX-Exoskeleton-Glove-001
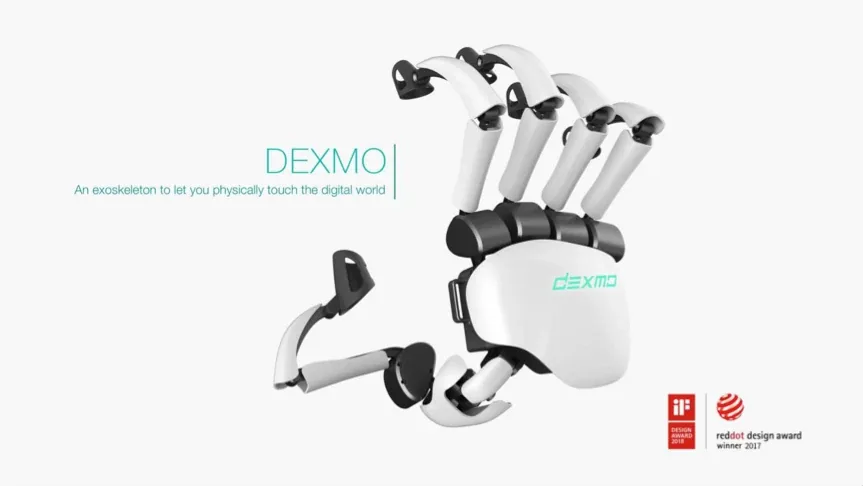
Articulated motion capture with variable finger resistance.
Follow finger bending, spreading and thumb rotation while shaping the resistance felt during a virtual grasp.
11 DOFMotion per hand
300 gDevice weight
2.4 GHzWireless link
Configuration profile
| Item | Specification |
|---|---|
| Motion capture | 11 DOF per hand |
| Thumb motion | Three tracked DOF |
| Other fingers | Two tracked DOF per finger |
| Feedback | Variable finger resistance and stiffness cues |
| Wireless connection | 2.4 GHz with receiver dongle |
| Wireless latency | 20–50 ms |
| Operating range | Within 5 m of the dongle |
| Battery | 1800 mAh; up to 8 hours in normal use |
| Integration environment | SDK and Unity integration workflow |
Specifications describe the reference configuration. Hardware, software and accessories are agreed for each project.
Plan the integration
- Fit the finger straps and verify each joint signal.
- Pair the receiver and establish hand-model alignment.
- Introduce resistance gradually and compare movement with the virtual hand.