
ZIXITECH · GLOVE CONFIGURATION
ZX-Force-Feedback-Glove-002
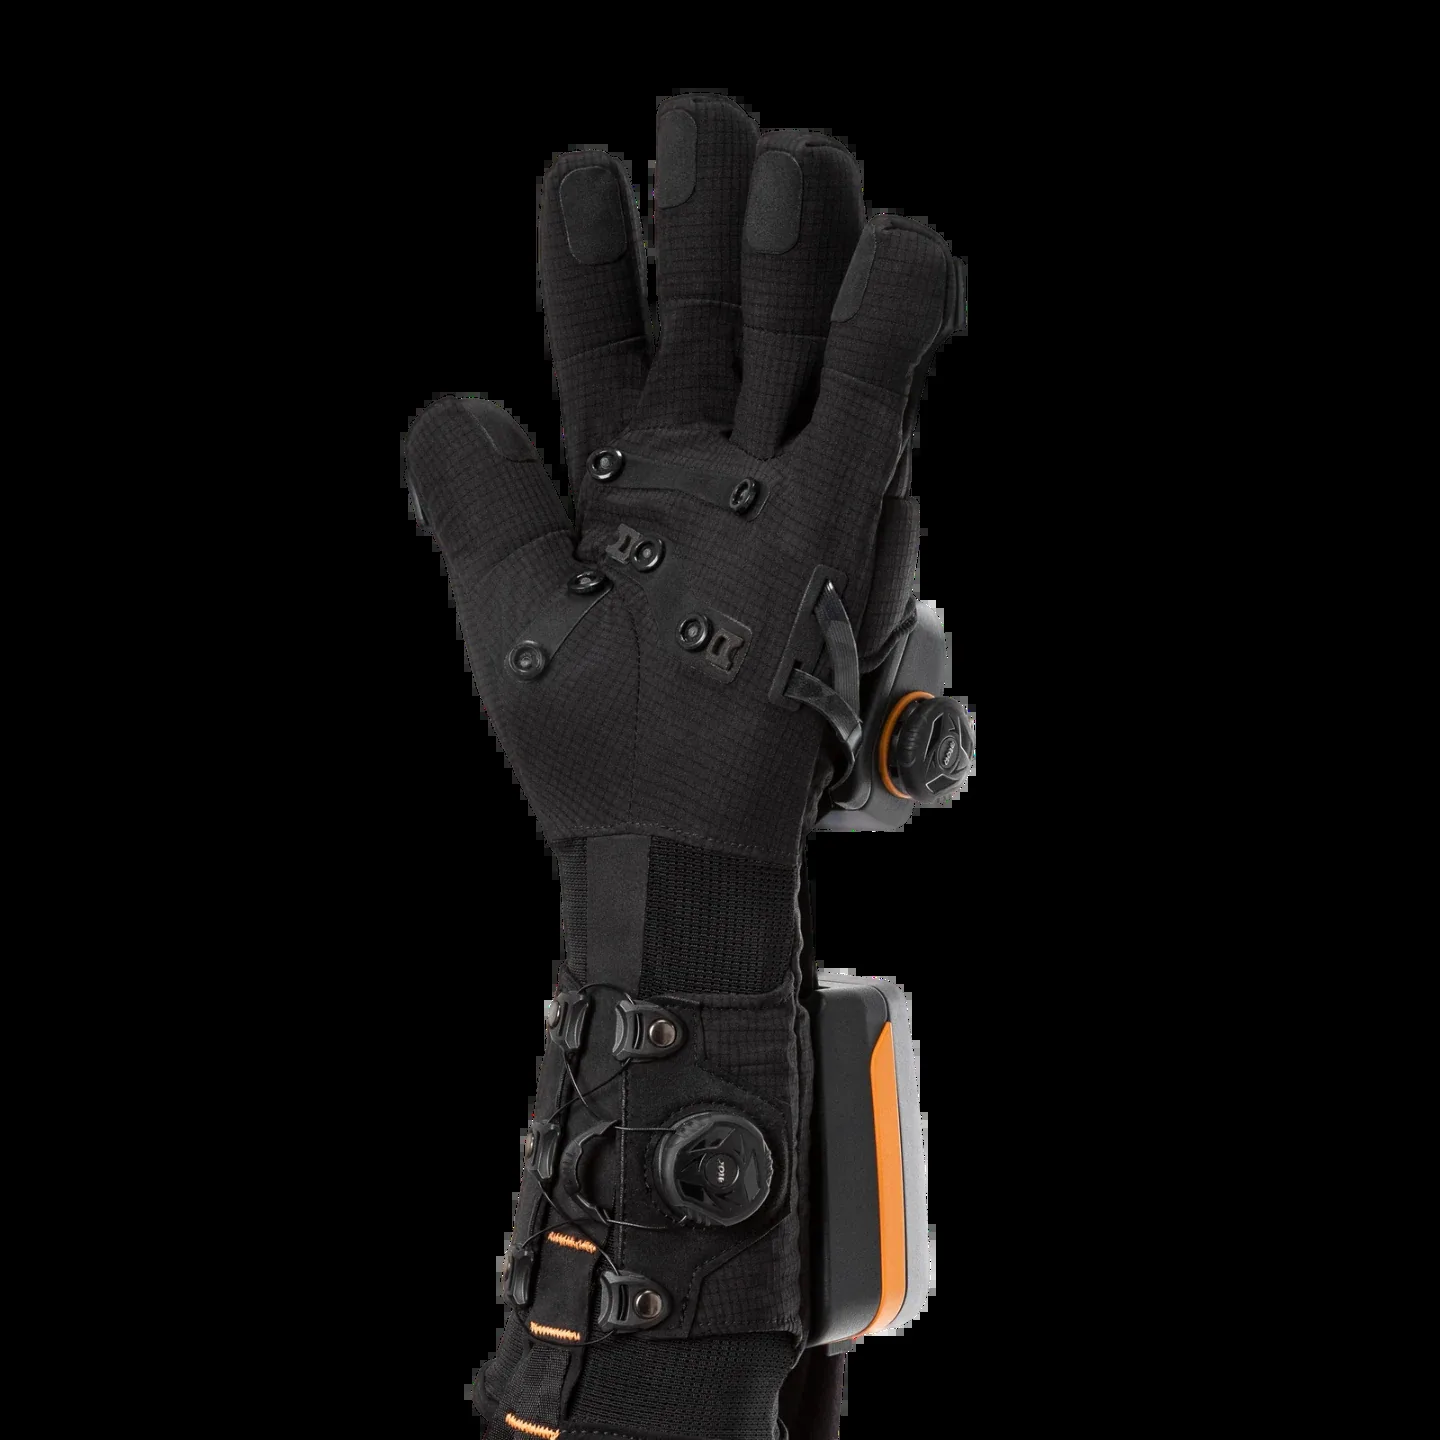
Distributed tactile contact and finger resistance for detailed haptic interaction.
A fluid-actuated configuration for exploring the shape of contact, grasp resistance and hand motion within the same task.
135Tactile actuators per glove
5Force actuators
120 HzMotion update
Configuration profile
| Item | Specification |
|---|---|
| Tactile array | 135 actuators per glove |
| Finger force channels | Five actuators per glove |
| Tracked motion | 36 DOF per glove |
| Motion capture rate | 120 Hz |
| Motion capture latency | 16 ms |
| Glove weight | 0.57 kg; glove only |
| Sizes | S / M / L / XL |
| System requirement | External pneumatic supply and host integration |
Specifications describe the reference configuration. Hardware, software and accessories are agreed for each project.
Plan the integration
- Select the glove size and desktop or mobile air-supply setup.
- Map the hand pose and review the feedback limits.
- Test a controlled contact task before a longer recording session.