
ZIXITECH · GLOVE CONFIGURATION
ZX-Force-Feedback-Glove-001
Cable resistance, fingertip vibration and palm contact in one wearable interface.
Explore grasp boundaries, object stiffness and contact cues while the operator controls a virtual or robotic hand.
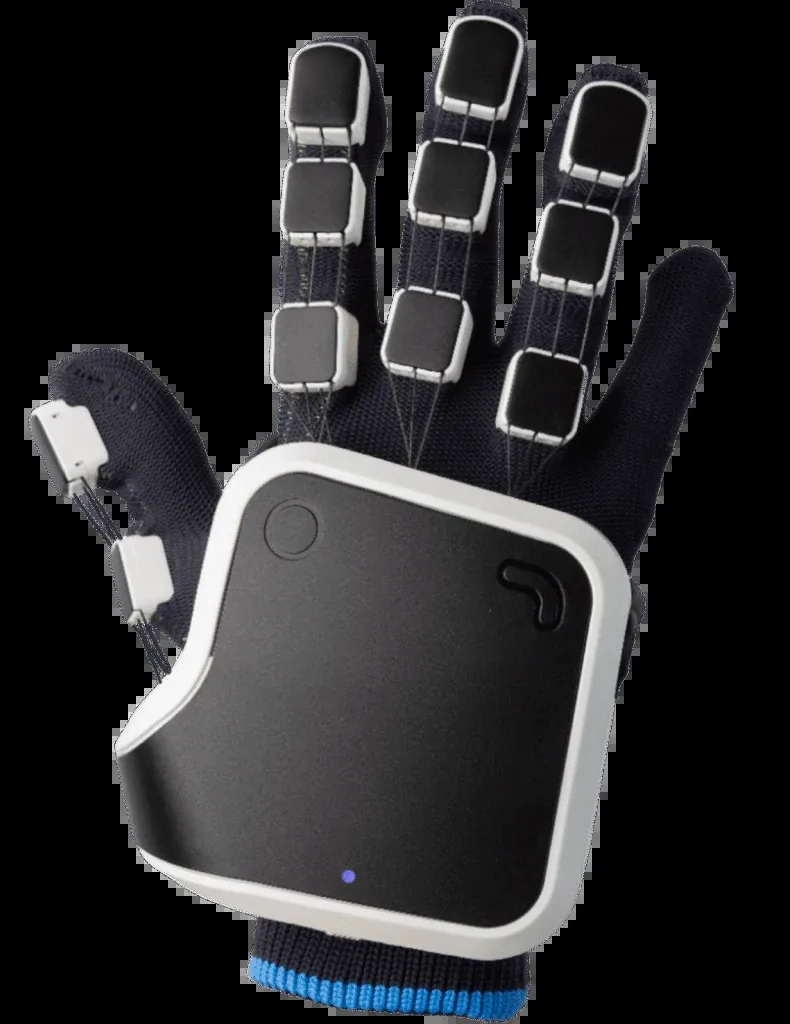
4Resistive finger channels
20 NPer equipped finger
4Vibration actuators
Configuration profile
| Item | Specification |
|---|---|
| Force channels | Thumb, index, middle and ring fingers |
| Force resistance | Up to 20 N per equipped finger |
| Force command rate | Up to 200 Hz |
| Vibration arrangement | Two fingertip and two palm actuators |
| Palm contact | Active strap travel up to 5 mm |
| Finger sensing rate | 60 Hz cable-extension measurement |
| Spatial position | External wrist-position tracker configuration |
Specifications describe the reference configuration. Hardware, software and accessories are agreed for each project.
Plan the integration
- Calibrate the finger motion and tracker alignment.
- Tune resistance and vibration cues for the chosen task.
- Log motion, feedback commands and task events together.