
ZIXITECH · GLOVE CONFIGURATION
ZX-Motion-Capture-Glove-001
Finger motion input for dexterous-hand demonstrations and robot teleoperation.
Capture finger flexion, map the motion to a target hand and rehearse a repeatable manipulation task.
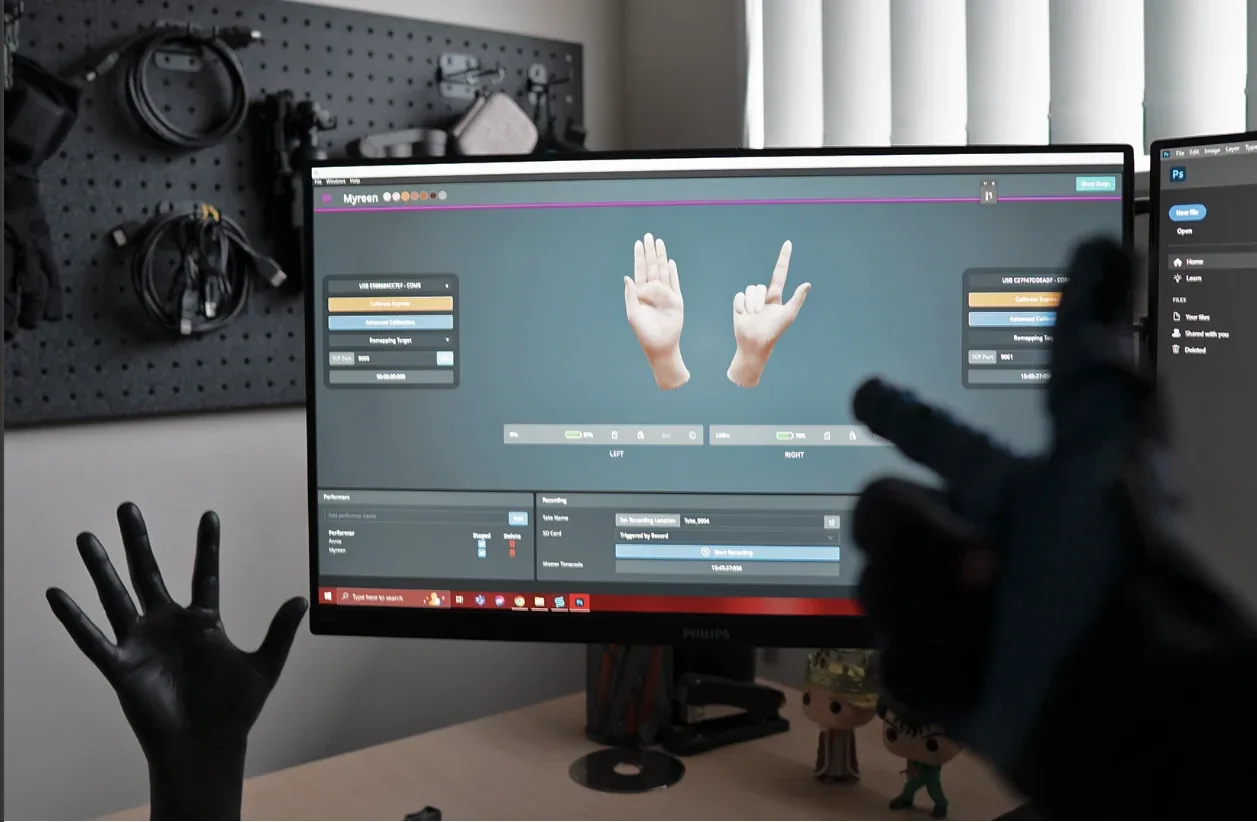
15 DOFFlexion reference layout
5Fingers to map
PoseOperator input
Configuration profile
| Item | Specification |
|---|---|
| Input | Finger flexion and hand gestures |
| Tracking layout | 15 flexion DOF reference configuration |
| Feedback configuration | Motion input without active force resistance |
| Robot interface | Joint mapping to the selected robot hand |
| Recording scope | Operator pose, target-hand commands and task events |
| Project setup | Glove fit, hand model, controller and connection |
Specifications describe the reference configuration. Hardware, software and accessories are agreed for each project.
Plan the integration
- Fit the glove and record a relaxed open-hand pose.
- Map one finger at a time to the target hand.
- Record a short grasp and review the hand motion and timestamps.