
ZIXITECH · GLOVE CONFIGURATION
ZX-Motion-Capture-Glove-002
Multi-sensor hand tracking for pose recording and robotics integration.
Combine finger, forearm and hub measurements to build a hand-pose stream for mapping and analysis.
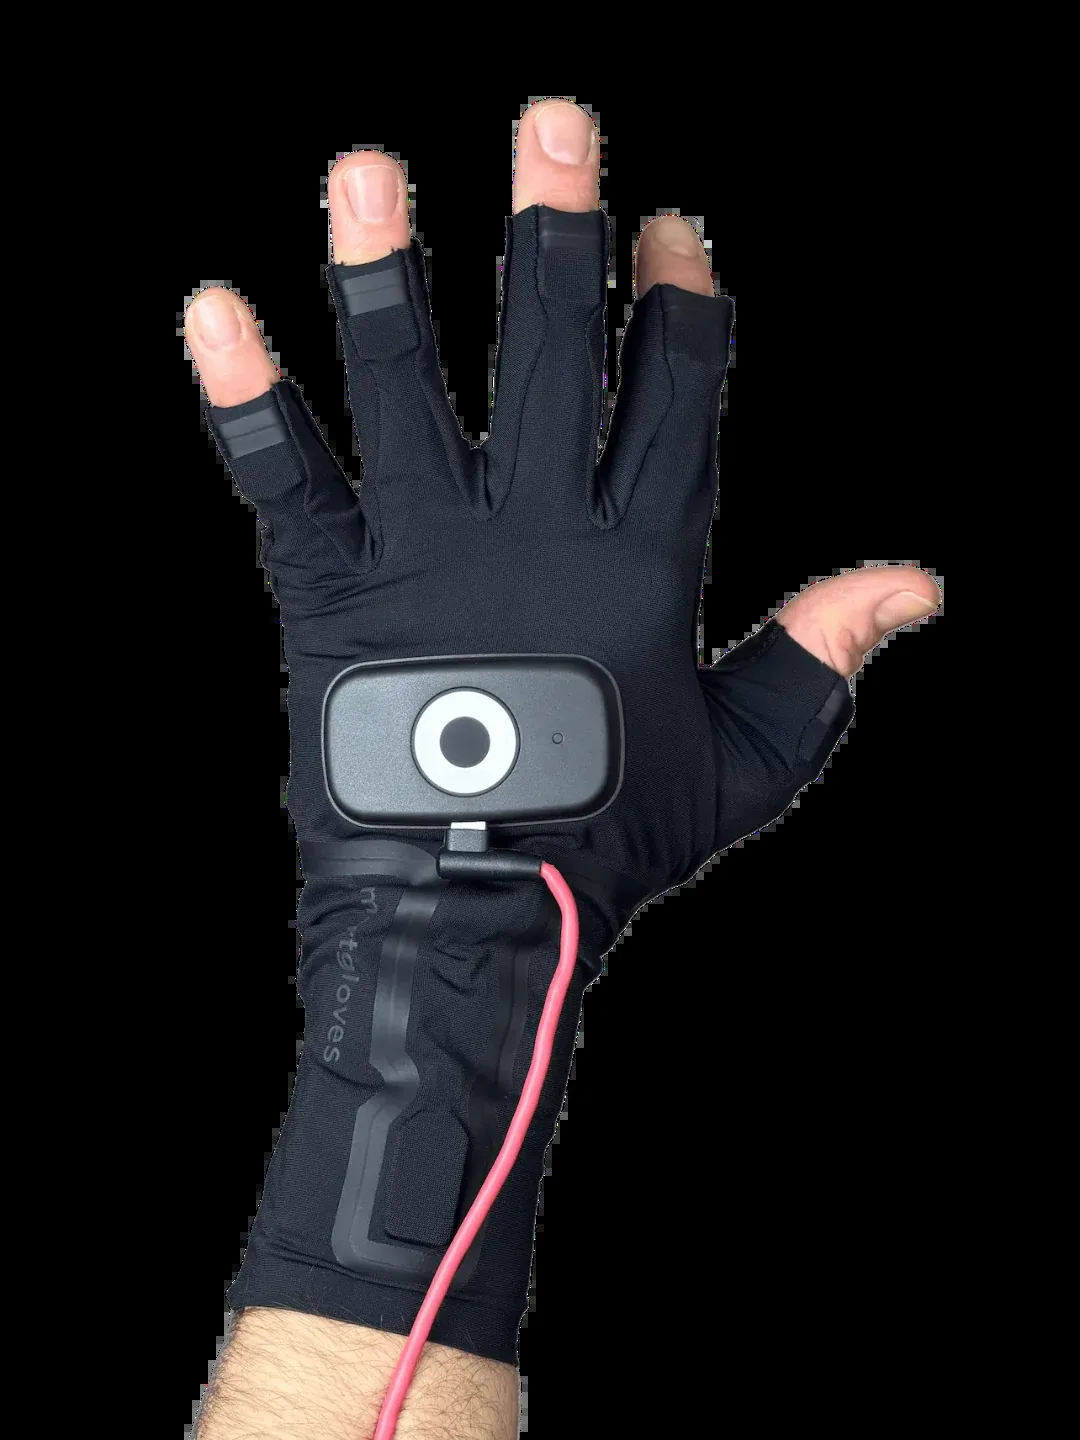
5 + 1Finger and arm nodes
250 HzIMU sampling
USB / Wi-FiData connection
Configuration profile
| Item | Specification |
|---|---|
| Sensing arrangement | Five finger sensors, one arm sensor and a central hub |
| IMU sampling rate | 250 Hz |
| Device output rate | 83.33 Hz |
| Pose coordinates | 39 driver-output DOF; sensor poses and hub orientation |
| Data connection | USB or Wi-Fi streaming |
| Latency definition | Motion to device-service output: 19 ms USB / 20 ms Wi-Fi average |
| Reference rate distinction | IMU sampling and device output are different rates |
Specifications describe the reference configuration. Hardware, software and accessories are agreed for each project.
Plan the integration
- Review the hand model and sensor reference frames.
- Connect the selected stream to a host recorder.
- Check finger tracking, mapping and time alignment on a representative motion.