On this page
Contact, recorded on a glove
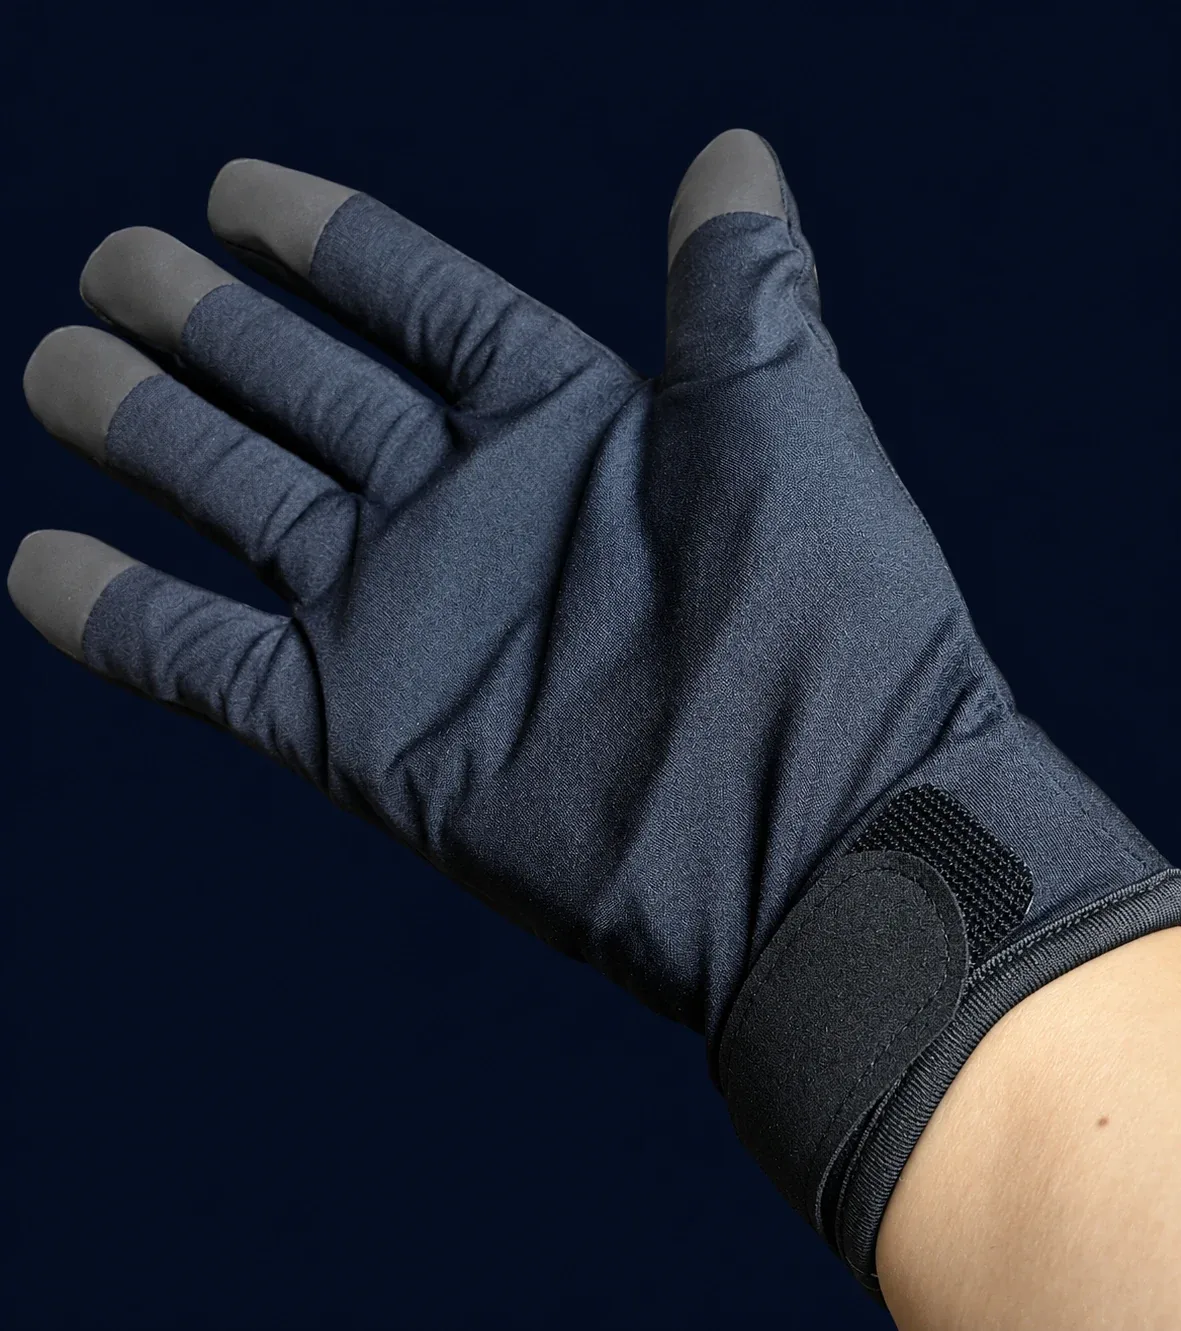
A tactile data collection glove records contact as a person handles objects. The useful starting point is where and when the hand meets the object.
- Confirm which hand regions are sensed.
- Ask what each channel measures.
- Do not assume every glove has full-hand coverage.
Contact is different from pose
Hand pose describes movement or configuration. A tactile signal describes interaction at a sensed location. If the task needs both, define two data streams and how they will be recorded together.
Read the channel map first
Ask for a map connecting each recorded channel to its location on the glove.
- Raw reading or calibrated physical value?
- What are the units and calibration conditions?
- Measured channel or software estimate?
How a tactile array becomes a data stream
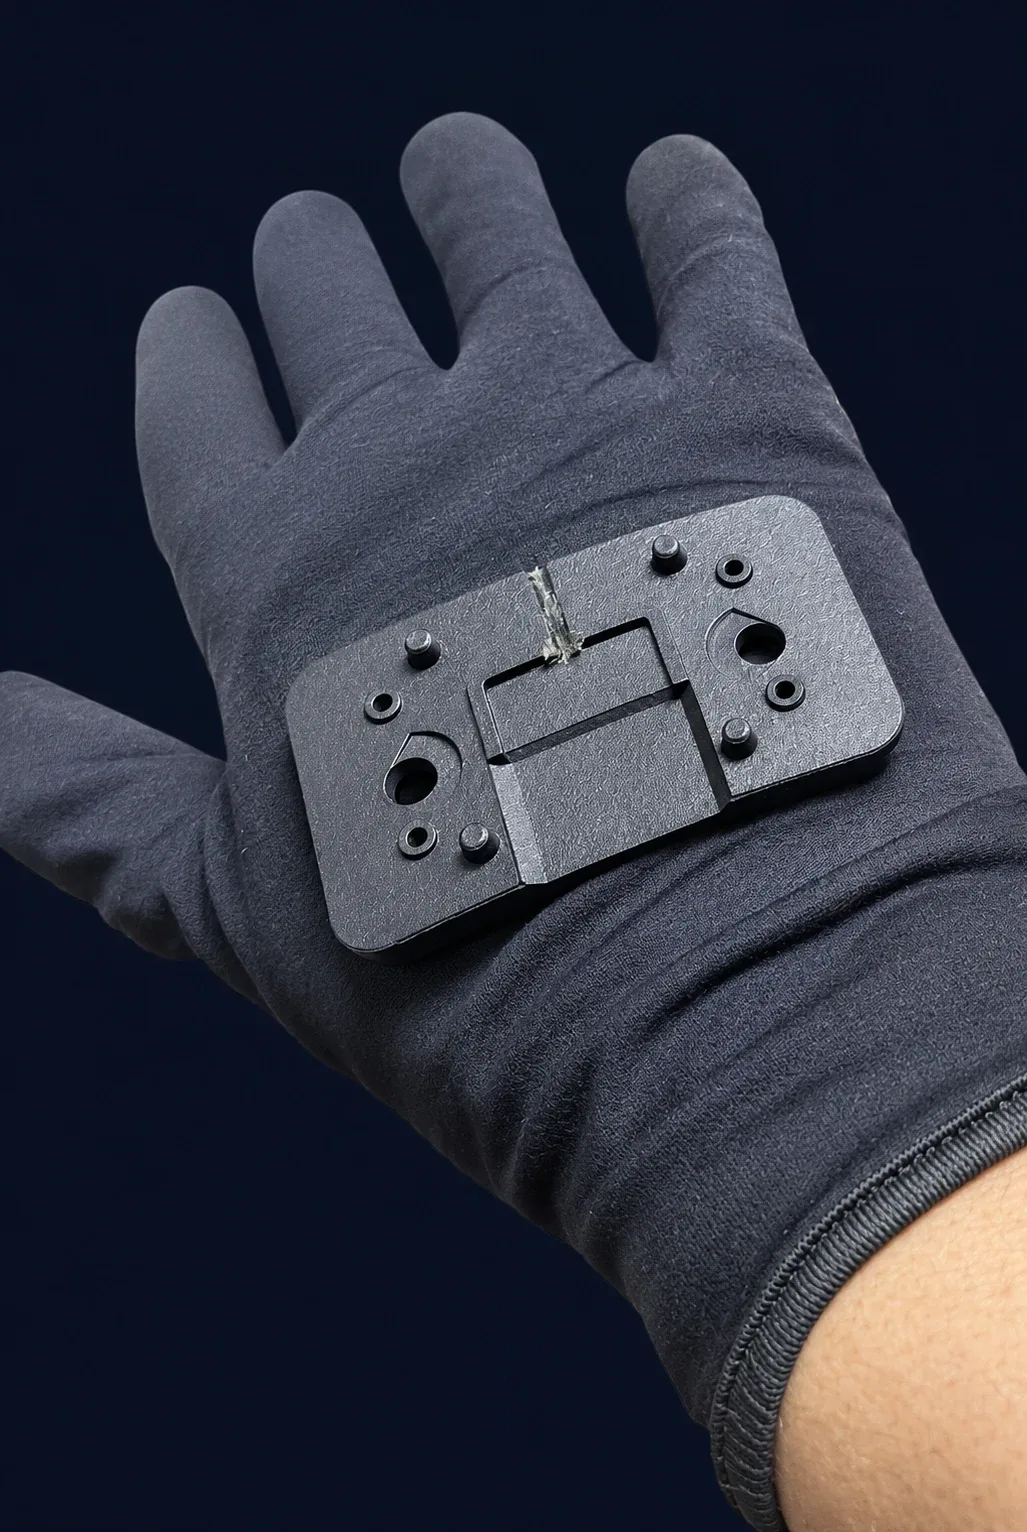
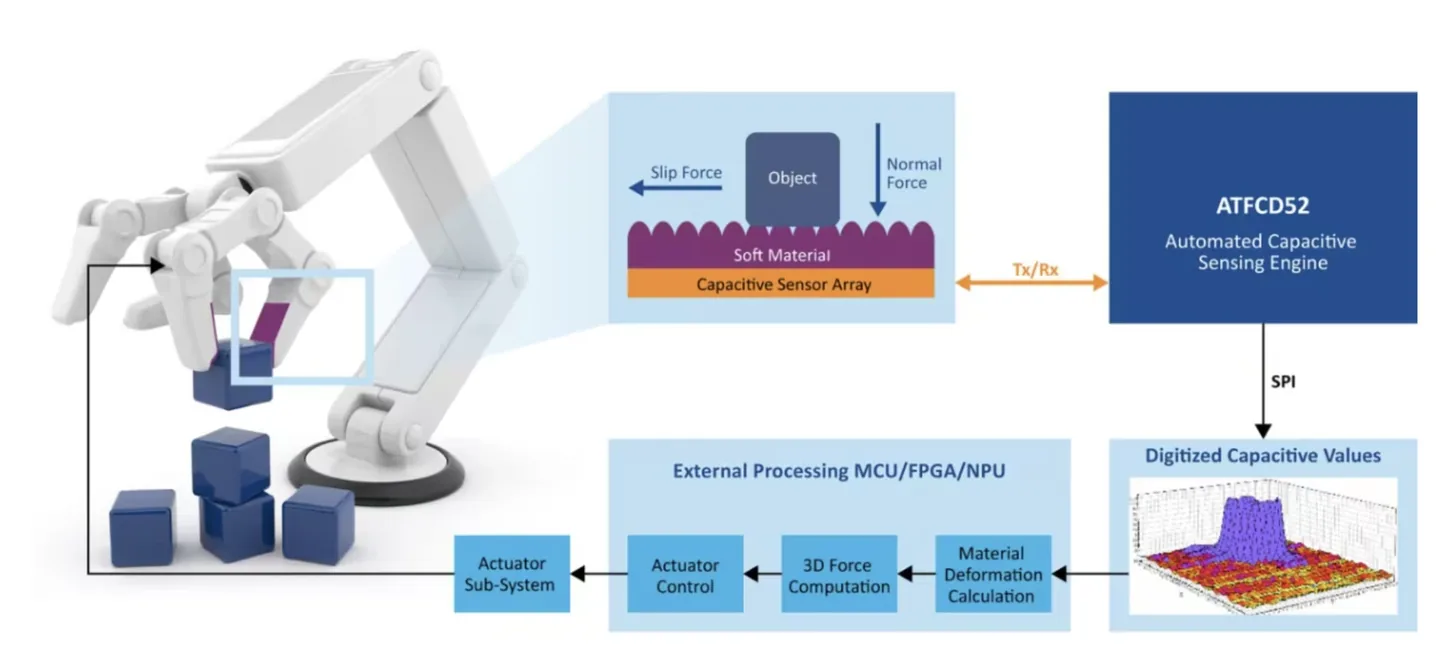
In this example, contact deforms a soft layer above a capacitive array. The digitizer reads changes in capacitance, and an external processor can use those readings to estimate force. A project brief should specify whether it needs raw sensor readings, calibrated measurements or a force estimate.
Make the first recording small
Use one representative object and a repeatable handling sequence.
- Pick up
- Hold
- Release
- Mark the beginning and end of the recording.
- Confirm timestamps and any video alignment.
- Save the hardware and calibration versions.
A research example
MIT CSAIL’s STAG research illustrates recording contact patterns across the hand during grasping. It is a separate research system, not a specification or validation of ZixiTech ZX-Sensor-Glove-001. Human glove channels should not be assumed to transfer directly to a robot.
Plan a tactile glove trial
Share a short task description and the signals you want to inspect.
- Objects and hand regions of interest
- Host environment and desired export
- A representative recording with its signal dictionary