On this page
Two different questions
Data glove is a broad term. Here is the distinction used in this guide.
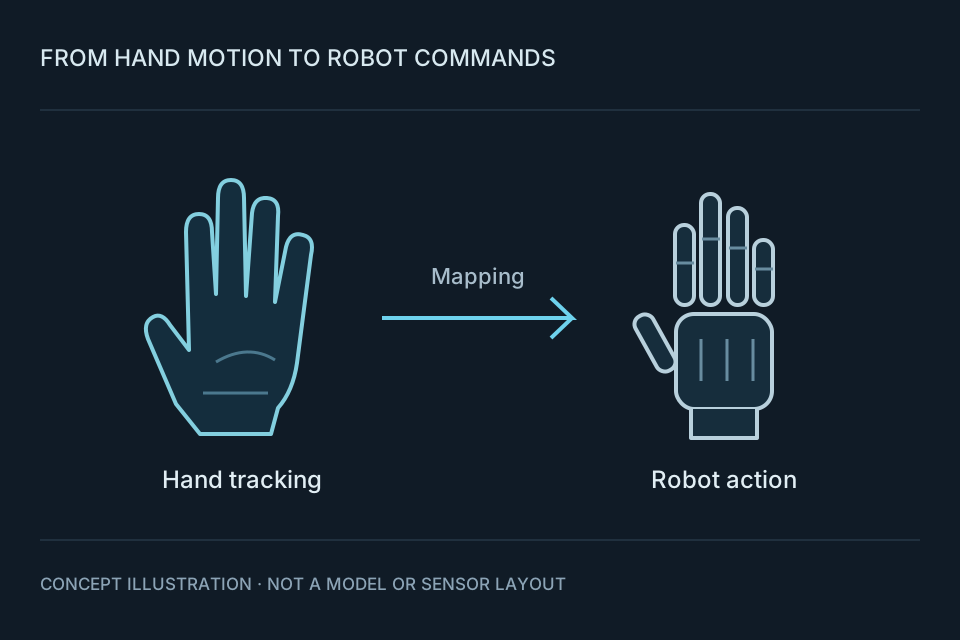
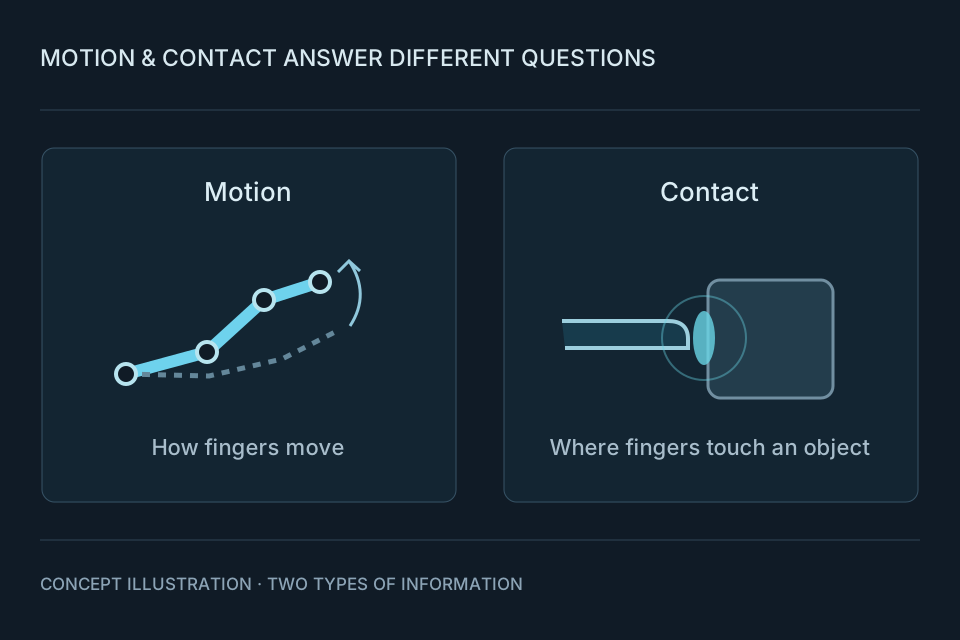
Motion capture
How does the hand move?
Look for the gestures, orientations or positions your task needs.
Tactile collection
Where does contact happen?
Identify the sensed hand regions and the meaning of their signals.
Let the task choose the signals
Choose a short action you need to observe.
- Movement task: identify the gestures or joint movements to track.
- Contact task: identify the hand regions and contact events to record.
When you need both
Define the motion and tactile streams separately before planning combined capture.
- Confirm timestamps and signal alignment.
- Agree on recording software and export.
- Try the complete setup before collecting a dataset.
Before choosing hardware
Ask for a configuration-specific explanation of the outputs.
- Sensing coverage and signal definitions
- Hardware interfaces and host environment
- Fitting and calibration instructions