On this page
Start with an action
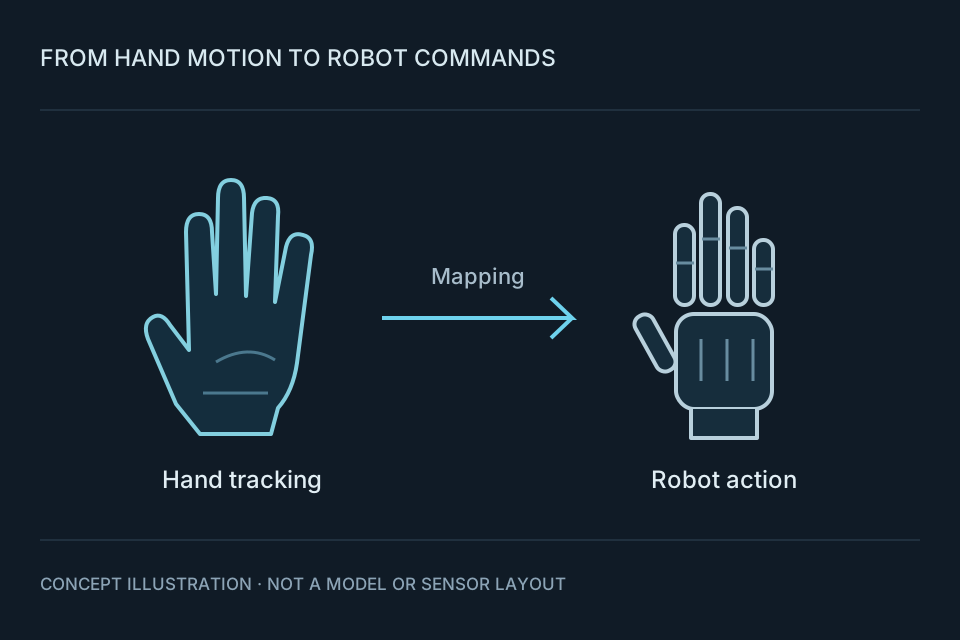
Motion capture records hand movement. Robot teleoperation also needs a way to turn that movement into robot commands.
- Open
- Pinch
- Release
- Identify the actions your task needs.
- List the robot joints that must respond.
Name the output
Ask for data definitions and an example file.
- Joint orientations, fingertip positions or solved hand pose?
- Which coordinate frames and units?
- Which values are measured or reconstructed?
Confirm the tracking configuration
Compare the tracking principle and the outputs available from the exact hardware and software version. A magnetic-inertial glove and an inertial glove may need different setup, calibration and checks.
Separate fitting from mapping
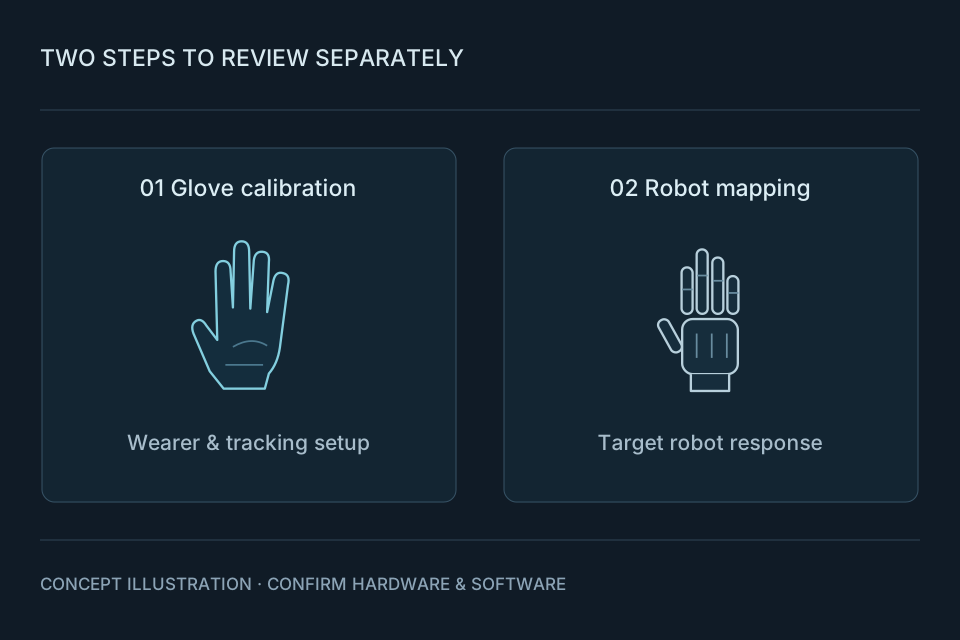
Glove calibration concerns the wearer and tracking setup. Robot mapping concerns how a different mechanical hand responds.
- Confirm the fitting and calibration procedure.
- Agree on software and mapping responsibilities.
- Check gestures in a controlled trial before object handling.
Compare the complete workflow
A rate or latency figure needs context.
- Which connection mode was measured?
- Does it describe sensing, transmission or the full control path?
- What host, software and connection were used?
Match the exact documentation
The supplier lists G2-L separately. Confirm applicability before using G2-L instructions for G2.
- Model-specific manual and data definitions
- Supplied software version
- Configuration-specific packing list